Chen Yizhou
The University of Hong Kong · School of Computing and Data Science

The University of Hong Kong
School of Computing and Data Science
Room 416, F core, Cyberport, Pokfulam, Hong Kong
Tel: (+852) 97004508
E-mail: yzhchen@hku.hk
Dr. Yizhou Chen is a Postdoctoral Fellow at the School of Computing and Data Science, The University of Hong Kong, working with Prof. Jia Pan. His research interests span robotics and machine learning, focusing on long-horizon, generalizable bimanual manipulation, imitation learning, and task and motion planning.
Yizhou received his Ph.D. (2019–2023) from the Department of Mechanical and Automation Engineering at The Chinese University of Hong Kong, advised by Prof. Ben M. Chen.
Yizhou’s honors include Best Paper in Automation Finalist at IEEE ROBIO 2024 and Research Talent Hub Scholar under Hong Kong’s Innovation and Technology Fund (2024). His academic service includes Associate Editor for ICRA 2027 and ICCA 2024, as well as reviewing for journals and conferences including IEEE T-RO, IEEE RA-L, RSS, ICRA, and IROS.
news
| Sep 28, 2026 | Our paper “Decompose and Reorganize: Planning with Primitives and Visuomotor Policies Learned from Demonstrations” has been conditionally accepted by IEEE T-RO, and the code is released as open source. |
|---|---|
| Jul 01, 2026 | Our paper “Keypose Exploration: Efficient Automatic Trajectory Labelling and Cross-Embodiment Policy Transfer” has been accepted by IROS 2026. |
| Apr 01, 2026 | Our paper “Semantically Structured Mixture-of-Experts for Compositional Robotic Manipulation” has been accepted by RSS 2026. |
| Dec 01, 2025 | Our paper “BiKC+: Bimanual Hierarchical Imitation with Keypose-Conditioned Coordination-Aware Consistency Policies” has been accepted by T-ASE 2025. |
| Dec 01, 2024 | Our paper “Synergistic temporal logic planning for an aerial gripper” is selected as Best Paper in Automation Finalist of ROBIO 2024. |
selected publications
- TASE
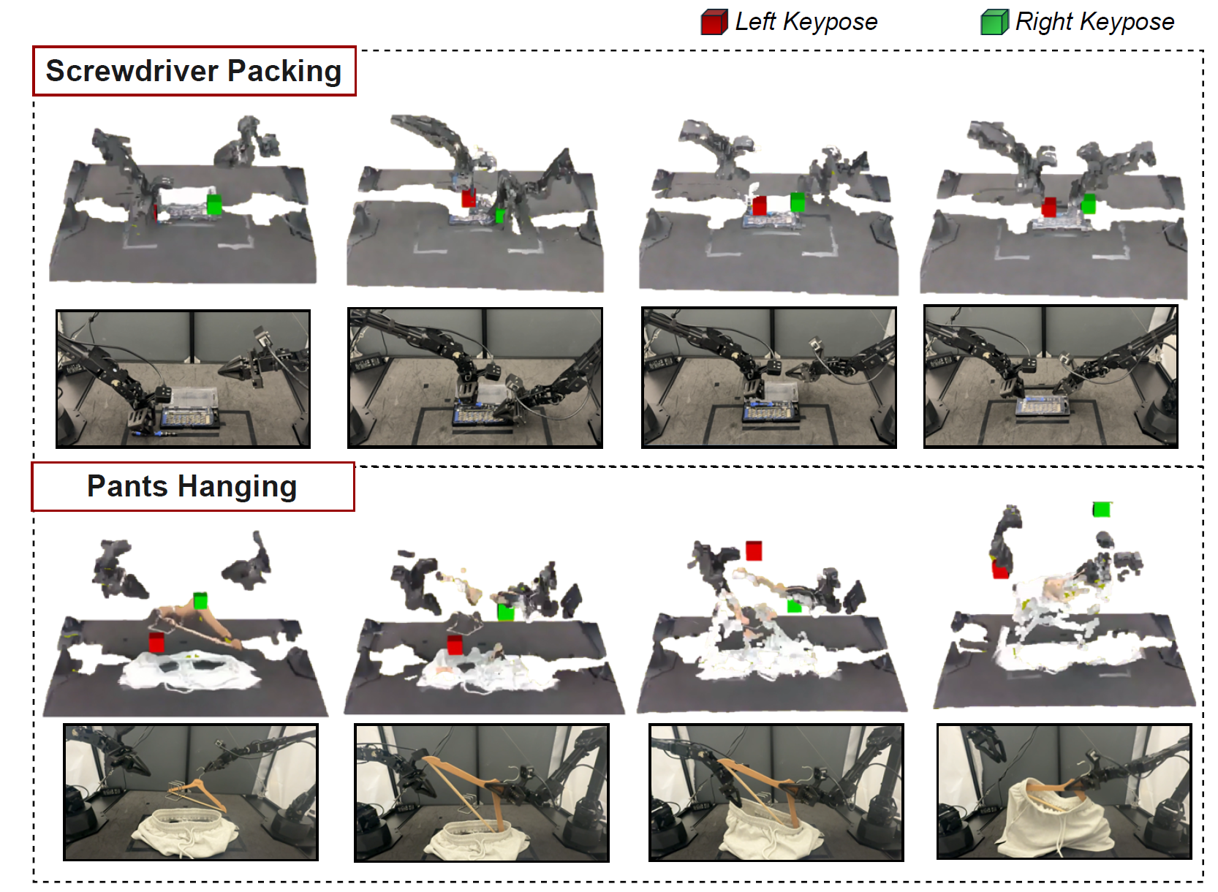 BiKC+: Bimanual Hierarchical Imitation with Keypose-Conditioned Coordination-Aware Consistency PoliciesIEEE Transactions on Automation Science and Engineering,Yizhou Chen is the co-corresponding author